ABOUT ME
My name is Rin Ray (they/them), and I’m a researcher-artist. My current math research is on arithmetic patterns in homotopy theory and physics.
Before the math and alongside: measurement and inference where the observable is missing, degraded, or not addressed to the observer — in biology, neural signals, robotics and physics.
Here for… the science ↓ the math ↓ the art ↓
I build instruments for overhearing. Across mathematics, scientific computing, biological systems, robotics, and art, I am interested in things that cannot be observed directly: a neural intention, an animal’s affective state, a body’s internal signal, a physical parameter, a mathematical structure.
I look for the traces they leave behind, and build ways to make those traces legible.
THE PATH
I am currently a postdoc at Uni-Münster in the Arithmetic and Homotopy Theory Working Group led by Thomas Nikolaus and Christopher Deninger.
Before that, I graduated from George Mason University at 16 with a B.S. in Computational Physics, and accepted the Thiel Fellowship in 2014 to develop medical technology and study mathematics under my mentor, Edward Frenkel.
I came to mathematics from the laboratory, and never really left: computational physics, robotics, machine learning on biological signals, and medical devices since 2011. That work is in The Lab, below.
Interview — WIRED, on Medical Tech
I graduated with my Master’s degree from UChicago working with Peter May and Kazuya Kato (加藤 和也), and with my PhD from Northwestern working with Paul Goerss. Yifeng Liu advised me too, without the title.
Here for the math? Skip to the research ↓
THE LAB
I build things, and I believe almost anything will answer you if you are willing to learn how it speaks. What I have spent my time building, mostly, is instruments for overhearing. A blinded robot, feeling for its own hand. Rats, telling each other how they are feeling. A cat, feeling for his colon. A brain, through the scar it grows around anything that listens. Half a page of Braille, about the missing half. Arithmetic, about superconductors nobody had made yet. A drone and a wheelchair, microwaved argon and a plate of food, a face, septic blood — and others. There are always others.
Most of this came before the mathematics found me — or before I found it. Two threads have remained in my hands: a cluster of diseases that keep showing up together and keep being treated apart, and a treatment that works and was never written down.
I build things, and I believe almost anything will answer you if you are willing to learn how it speaks. For over a decade I have studied the three kinds of silence: what is absent, what is fading, and what is spoken in another room. Three threads remain in my hands: a cluster of diseases that keep being treated apart, a treatment that was never written down, and a cheap drug for pain that nobody will test.
A decade of work on measurement and inference where the observable is missing, degraded, or not addressed to the observer: motor intention from a thinning population of cortical units, affective state from ultrasonic vocalization, proprioception without vision, lexical structure from partial parallelism, superconducting transition temperature from electronic structure.
Living things
Hidden states, read from the traces a system emits.
Sensory Sensitivity as a Unifying Mechanism2024 – ongoingcurrent
Sensory processing as an organizing principle · gut microbiome · autoimmunity · chronic pain · glutamate excitability · joint with Luca Estinto
The people I interviewed about wheelchairs kept telling me about pain, and pain was the thing nobody had an answer for. Years later the same shape kept appearing: autoimmune conditions, gut trouble, chronic pain, sensory sensitivity, and certain neuropsychiatric diagnoses turning up together in the same people and being treated by five different specialists who never speak to each other.
Restarting the nerves that move a colon2026current
Feline idiopathic megacolon · enteric motility and cholinergic transmission · neostigmine · owner documentation of an unpublished treatment
A cat of mine was dying because his colon was paralysed, and the two options put in front of me were surgery and euthanasia. He was too heavy and too unwell to survive the anesthetic, so in practice that was one option. There is a third, and it is not in the literature: it circulates as folklore between practitioners, never reaches a journal, and so whether it is offered to your animal depends almost entirely on who you happen to be standing in front of that day.
The six-cent drug nobody will test2026current
Memantine · NMDA receptor antagonism · central sensitization · opioid tolerance and hyperalgesia · drug repurposing · trial design
People who use mobility aids told me they were choosing every day between being stoned past the point of finishing a sentence and being lucid and in agony. I wanted to know whether anything avoids that choice.
Learning the ultrasonic language of ratslate 2013 – mid 2014
Computational bioacoustics · unsupervised clustering of rodent ultrasonic vocalizations · quasi-real-time monitoring in the animal’s own cage · preclinical safety pharmacology · affective-state readout · 3Rs refinement
A mouse cannot report a symptom, but it is talking constantly in a register we cannot hear. Two things follow from listening properly. You get some understanding of what these animals are actually saying to each other. And you get far more out of each experiment while doing far less to the animals in it: a microphone over a cage takes readings continuously, at night, in the dark, from an animal nobody has touched, picked up, restrained or moved to a testing room — which is both a kinder life and a cleaner measurement, since a frightened mouse is not the animal you meant to study. More information out of every cohort, less disturbance per animal, and a clearer picture of what a compound does before it goes anywhere near a person.
A multi-company validation in 2025 put three compounds that had passed conventional safety pharmacology under continuous non-invasive monitoring in their own cages and found signals anyway, some persisting for days after dosing. Quietly watching animals who are left alone turns out to see things that handling them on a schedule does not.
The signal under the scarSummer 2014
Intracortical brain–computer interfaces · decoder convergence analysis · foreign body response and chronic signal loss · optical recording
Neuroprosthetics have two major issues. At the tissue end, putting an electrode into a brain is an injury: microglia arrive, astrocytes proliferate, and a glial scar closes around it, pushing the neurons you wanted away from the thing that is listening — so the signal thins and gets noisier across the months in which a person is coming to depend on it. At the other end, any single neuron tells you almost nothing; the intention to move is legible only across a whole population of them. I came at this from the software side and assumed both were software problems. My first thought was that a decoder which recalibrated fast enough could just track the signal as it drifted — that convergence was the thing to fix. I worked on that for a while before accepting you cannot infer your way out of an electrode with fewer and fewer neurons left to hear.
Most of the answer has been materials. The stiffness mismatch is absurd — silicon around 180 GPa against a brain of a few kPa — so the field went soft: ultraflexible polymer threads, mesh electronics injected through a syringe, carbon fibers seven microns across, substrates stiff enough to go in and then soften once wet. In mice it works beautifully. One open-mesh design tracked the same neurons for thirteen months, most of the animals’ adult lives. Coatings do the rest: PEDOT to drop impedance, neural adhesion proteins, dexamethasone eluted to quiet the response. Then the uncomfortable part. Across fourteen BrainGate participants and up to seven and a half years, the arrays held spiking on about a third of their electrodes and declined only about seven percent — and when arrays are taken out and examined, the leading failure is the silicon eroding and the metal coming away, not the tissue closing in. Softer probes may be the right fix for the wrong failure. “Scar-free” was a mouse result in 2017 and has been quoted a long way past its evidence. Meanwhile the thing these arrays turned out to decode best was not a limb but speech, which in 2014 I would not have guessed at all.
A laboratory on a keyring2011 – 2014
Point-of-consumption allergen detection · laser absorption spectroscopy · G12 antibody colorimetric assay · immunoassay cost and sampling limits
For someone with celiac disease or a severe food allergy, every meal they did not cook themselves is an act of trust in a stranger, and the cost of that trust being misplaced runs from a ruined week to a funeral. The idea was to hand the judgment back to the person eating, in something small enough to live on a keyring.
In March 2014 I found GlutenTox, TellSpec and 6SensorLabs already at it — the good kind of disappointment. 6SensorLabs became Nima, which shipped in 2017, missed gluten at the legal threshold more than a fifth of the time, died in 2020, and came back in 2026 claiming 10 ppm, by its own measurement. My wall got routed around rather than climbed: the expensive part was the antibody, and the field swapped it for aptamers, synthetic DNA that folds around a target for a fraction of the cost. One 2024 design reads gliadin off gold nanoparticles with a phone camera. The part underneath is still unsolved: a negative on one bite does not clear the plate, and sampling error swamps measurement error.
Polyglass — reading a pulse off a face, and why I would not build it nowHackMIT 2013
Remote photoplethysmography from video · contactless physiological sensing on a head-mounted display · consent and surveillance ethics
The idea was to help autistic people read social communication: if the signals everyone else is supposedly picking up on are real, a machine ought to be able to surface them.
I would not build this now. It takes a reading off someone’s body without their knowledge and gives them no way to refuse — the person being measured is the one person in the room with no say in it. The need was real; meeting it this way moves the cost onto somebody who never agreed to carry it.
Bodies in motion
A body reading the traces of its own movement.
Fixing what is wrong with wheelchairs2013 – 2015
Modular retrofit robotics for powered wheelchairs · automated pressure redistribution · powered seat elevation · assisted transfer · rough-terrain drive · user-led requirements · gaze-controlled assistive mobility · mentorship
My grandfather lost his mobility, so I volunteered at a spinal cord injury rehabilitation unit and asked the people there: What would improve your quality of life? Three answers kept coming back: getting between bed and chair, being at eye level in a conversation, and ground rougher than the floor the chair was built for. Separately I went looking at what actually kills people with spinal cord injuries. Mostly infection, and an open pressure sore is one of the ways infection gets in. They are not the biggest killer — that is pneumonia; they are the biggest killer mechanical engineering can do anything about.
- five robotic pressure-injury relief mechanisms, shifting the occupant’s load without them having to do anything — depending on someone to remember it, which many cannot, fails on exactly the days they are unwell
- a transfer mechanism, for getting between bed and chair
- a seat that rises, for talking at eye level
- a drive and tires for ragged ground
I expected to hear about getting around. What I kept hearing about was pain —
constant, and largely unaddressed by anyone they had seen.
It was not a thing I could answer with mechanical engineering. What I could do was
make sure the mechanisms were not locked up: I wrote up all the mechanical engineering
and soft robotics I’d invented as a nonprovisional patent application,
Robotic Mobility Assistive Wheelchairs, and then decided not to file it, and
they went out under a Creative Commons license instead. A patent would have meant the
people I built them for waiting on somebody else to license it first.
Then I went to work on understanding and treating chronic pain, which I am still doing.
Both halves have since arrived, about a decade on. Medicare began covering powered seat elevation in 2023 — on the grounds of transfers and reach, not of meeting people at eye level, which is what the users I spoke to actually said. And automated pressure redistribution that asks nothing of the occupant is now a pilot study. I should say plainly that all of this, mine included, measures interface pressure, which is a proxy; nobody has shown it prevents an injury.
When the cameras die, the hands take overSummer 2012
Proprioception-only contact-rich manipulation · blind peg-in-hole insertion · two-arm load equalization · Willow Garage PR2 · human–robot interaction
Blindness in robots. A machine that stops dead the moment its camera fails is a machine you cannot trust around people, and sensors fail constantly.
What is recoverable once a sense is gone?
The Braille work, the following spring. Here, a robot reaching for a hole it cannot see and finding it by touch; there, a language meant to be read by touch, worked out from fragments by a machine that cannot see either. Both are asking what is recoverable when the channel everyone assumes you have is missing.
Drawing the map while flying through itFall 2012
Simultaneous localization and mapping · monocular visual SLAM with parallax bootstrapping · loop closure · scale from sonar and inertial fusion · motion planning on a partial map
To know where you are, you need a map. To build a map, you need to know where you are. So how does anything ever get off the ground?
I would not take this on now. Navigating terrain nobody has surveyed is not a neutral capability — there is very little daylight between solving it for a toy quadcopter and solving it for something armed. I was treating it as a puzzle about maps and motion, not thinking of the consequences.
The homesickness robot2011
Mimicking animal motion and companionship · robot person following · gait-based re-identification · statically stable hexapedal locomotion
My first robotics project, and the motive was homesickness — I missed my dog at university, so I built something that would trail after me.
The way out was not more legs, even though I personally find that cuter. Boston Dynamics went the other way with BigDog — four legs, which cannot fall back on geometry at all and so have to catch themselves, force-controlled limbs choosing where to put a foot in the next fraction of a second. That is the machine everybody remembers getting kicked sideways on ice and skittering back upright, and it is the approach that generalized. Quadrupeds now learn the recovery in simulation and cross ground I could never have got a hexapod over. Following a person around has a name now too — robot person following — with benchmarks, and re-identification that keeps learning your target as they change.
What if, rather than planning motion across a floor, you add flight to the problem? Three dimensions, no ground to stand on, and no option to stop and think.
Matter
Behaviour inferred from the traces that structure leaves.
Calculating a material into existence2012 – 2013
Electronic-structure calculation · augmented plane wave method · superconducting transition temperature of intermetallic compounds · computational materials screening
A superconductor carries current with no resistance: nothing lost, nothing turned to heat, and magnets far stronger than their power draw. Every one we have needs liquid helium, so the chase is for one that works warmer — and you cannot run that chase by building candidates one at a time.
The approach paid off, in other people’s hands. H3S was calculated to superconduct near 200 K and then measured at 203 K; LaH10 was predicted in 2017 and found at 250 K two years later. Materials predicted on a computer before anyone made them, which is the outcome the whole approach was betting on. They need megabar pressures, so nobody is wiring a city with them yet.
Nothing interesting happens at only one scaleJan 2015
Multiscale modeling · directed type systems · compositional model building · topology applied to complex biological systems
A multiphysics simulation is several different physics solved over one domain at once, and it is expensive twice over: the run itself, and the human work of stitching solvers together without introducing errors. Both of those are structural costs, and the structure is already sitting there in the mathematics.
Other people were heading the same way, and one of my own co-authors on Toward Directed Collapsibility is among them: Nicole Sanderson now writes on topology and neural circuits. Persistent homology has reached the tumour microenvironment too, picking out rare T-cell states under checkpoint blockade. The immunotherapy daydream had other people in it all along.
Both halves have since been developed, independently of me. Directed type theory was rebuilt on synthetic simplicial foundations, where the objects under study are exactly cocartesian fibrations, and the proofs are going into a proof assistant. On the applied side, Decapodes composes systems of PDEs diagrammatically: you assemble a multiphysics simulation out of component models instead of editing a monolith, and the composite is a first-class object rather than a hand-merged file. They report a drastic drop in time-to-first-simulation, though they say plainly that the claim is qualitative and unmeasured, which is the honest state of it.
What shapes will a plasma hold?2012
Standing-wave mode structure of a 2.45 GHz argon discharge · conductive polyhedral cavity · deployable structures in ionospheric plasma
Space is cool, and a satellite that folds is cooler: you launch something small and it opens into something large. But a deployed satellite is a geometric mesh sitting in the ionosphere, which is a plasma, and that plasma is part of the electrical environment the structure has to work in. So the question is what a given geometry does to the fields around it.
People do this deliberately now and call them plasma metasurfaces: discharges arranged so their geometry decides which electromagnetic modes get through, and reconfigured by changing the discharge rather than the hardware. I was making a very crude one and calling it a side project.
A thinking film you could bendSpring 2012
Flexible TiO2 resistive switching · memristive device fabrication and bend-cycle characterization · in-memory computing
A memristor is a resistor that remembers where you last left it. That sounds like a small thing and it is not: a component that stores a value and computes with it in the same place means a device built from them does not have to send its data somewhere else to be processed. Put a memristor on a flexible surface and that device can be worn: potentially as a non-invasive medical device.
Years afterward, a group wired live rat neurons in Padova to silicon neurons in Zurich through memristors in Southampton, with the memristors holding the synaptic weights between them. The devices were Pt/TiOx/Pt — the same stack I had been making by hand. I had nothing to do with it, and it is still my favorite thing to have happened to a material I once held.
Fragments
Structure recovered from the traces a language leaves behind.
Reading a language from the fragments somebody already translatedSpring 2013
Unsupervised grammar and lexicon induction from partially parallel text · decipherment of incompletely understood scripts · contracted Braille as the test language · accessible signage
This started because I read Braille and kept noticing that the signs around me were wrong. The one that decided it: a door labeled electrical room in print and safety exit in Braille. Whoever installed it could not read what they were mounting, and nobody downstream of them could catch it. So I wanted translation to be something a builder could get right at the point of installing a sign, rather than something they had to take on faith.
The grammar was the problem, and the standards body agreed. When Unified English Braille replaced the older code, nine contractions were deliberately deleted — in BANA's own words, to enable accurate automatic translation and reduce the exceptions to the rules. They simplified the language rather than the model. It is still not solved: frontier language models today refuse, hallucinate, or emit malformed Braille, and a small fine-tuned model beats all of them.
Trying to keep clinical doctors up to date2013
Automated computational semantics · abstractive summarization of biomedical literature · evidence fidelity
I kept meeting working doctors who were further from the current literature than they wanted to be. Not for any want of caring: seeing patients all day and reading a stack of new papers every week are not two things one person can do. The volume is what defeats them, so the volume is what to go after.
This is the research CAMEL grew out of, pointed the other way round. There, meaning recovered from too little text; here, meaning kept intact while most of the text goes away.
Living things
Hidden states, read from the traces a system emits.
Sensory Sensitivity as a Unifying Mechanism2024–current
Synthesis arguing that failure of habituation constitutes a shared upstream mechanism, drawing on connectivity imaging, glutamatergic excitability, microbiome composition and enteric regulation of immunoglobulin secretion. With L. Estinto.
Hypothesis-generating; not experimentally validated.
Neostigmine in feline idiopathic megacolon2026current
Owner-reported case study of an acetylcholinesterase inhibitor used off-label to restore colonic motility, with lactulose and anti-NGF analgesia, documented to a standard usable in consultation.
Contraindicated without prior deobstipation and exclusion of mechanical obstruction. Medical management succeeds in roughly two thirds of cases presenting under six months and under six percent thereafter.
Memantine as a candidate non-opioid analgesic in central sensitization2026current
Review of the mechanistic rationale, comparative pharmacology against ketamine and dextromethorphan, and the clinical trial record for memantine in chronic pain, with a proposed design for a publicly funded trial.
Evidence synthesis only. The pooled analysis of eleven trials is not significant; the positive signal rests on one 63-patient fibromyalgia trial.
Unsupervised classification of rodent ultrasonic vocalization for continuous preclinical monitoring2013–2014
Unsupervised classification of rodent ultrasonic vocalizations in quasi-real time, deployed as a preclinical readout for compound effects on stress and libido — the first continuous non-invasive behavioral phenotyping system at Vium, several years before MUPET and DeepSqueak made the approach standard. Two write-ups: A New Female–Female Mouse Vocalization Discovered via Unlabeled Machine Learning and On the Detection and Prevention of Aggression in Lab Mice via Quasi-Real Time Analysis.
Non-contact acquisition removes handling stress as a confound and increases information yield per cohort; later multi-company validation supports the approach. Prior unsupervised USV clustering exists (Grimsley et al., 2013).
Decoder convergence and optical recording for intracortical motor prostheses2014
Convergence analysis of intracortical decoders under signal drift — how fast a Kalman-style filter settles onto a usable mapping from neural activity to intended movement, how far it degrades as glial scarring thins the neural population, and how much adaptive recalibration recovers. Then optical recording via fluorescent calcium indicators as an alternative to penetrating electrodes.
Foreign body response degrades yield; subsequent human longitudinal data indicates abiotic electrode failure may dominate. Optical methods remain depth- and delivery-limited.
Portable detection of gluten and common allergenic proteins2011–2014
Two approaches: a laser and avalanche-photodiode optical assay, abandoned for insufficient SNR against protein-rich matrices; then a G12 antibody colorimetric assay in a toothpick or strip format.
Limiting factor was antibody cost per assay, not sensitivity. Sampling variance in heterogeneous food exceeds measurement variance, which bounds the device class; aptamer assays have since addressed the cost term.
Remote photoplethysmography on a head-mounted display2013
Recovery of cardiac pulse and its variation from video alone, without contact, intended as a social-signal aid. HackMIT, with K. Talwar and S. Hewett.
Withdrawn on ethical grounds: the measured party cannot detect or refuse the measurement.
Bodies in motion
A body reading the traces of its own movement.
Modular robotic retrofits for powered wheelchairs2013–2015
Four assemblies designed to fit chairs already configured to their users: automated pressure redistribution, powered seat elevation, assisted bed-to-chair transfer, rough-terrain drive. Requirements elicited from wheelchair users with spinal cord injury; subsequent mentorship of gaze-controlled mobility assistance for ALS and SCI.
Written as a nonprovisional patent application and deliberately not filed; released under Creative Commons. Interface pressure is a surrogate endpoint.
Graceful degradation under sensor failure: contact-rich manipulation on proprioception alone2012
A robot that stops dead the moment its camera fails cannot be trusted around people, and sensors fail constantly. With vision and all external feedback disabled, a Willow Garage PR2 autonomously acquired a shape-matched insertion task from commanded joint positions and gripper sensing alone. Also two-arm load equalization for objects with off-center mass. HCI internship, George Washington University.
Demonstrates graceful degradation at the extreme: total loss of exteroception, not a partial fault. Learning was small-scale policy search.
Monocular visual SLAM with motion planning on a micro aerial vehicle2012
PTAM-class monocular SLAM, processed off-board, with metric scale recovered by fusing sonar altimetry and inertial measurement, coupled to frontier-based planning on a partially built map. Parrot ARDrone.
Bounded by repetitive texture, illumination change and airframe disturbance. Dual-use: unsurveyed autonomous navigation transfers directly to armed platforms.
Gait-based re-identification for robot person following2011
Hexapedal platform; target enrollment by proximity, association by gait rather than appearance, steering on bearing. Alternating tripod gait for statically stable traversal.
Static stability is a guarantee over an idealized contact model and does not survive real terrain.
Matter
Behaviour inferred from the traces that structure leaves.
Electronic-structure prediction of superconducting transition temperature2012–2013
Augmented plane wave band structure feeding an electron-phonon coupling estimate and a McMillan/Allen–Dynes transition temperature for intermetallic compounds. Advised by D. Papaconstantopoulos, George Mason University. Undergraduate thesis.
Subsequently validated at scale by the predicted-then-synthesized hydride superconductors, at megabar pressures.
Dependent and directed type systems for multiphysics models2015
Proposal that multiphysics models be expressed in a dependent type language. Classical fields are sections of fiber bundles; dependent types are semantically fibrations; the correspondence permits model structure, including direction of coupling, to be carried in the type and exploited by the compiler. Visiting researcher, Santa Fe Institute.
Motivated by run time rather than correctness alone: dependently typed elimination of runtime checks measurably reduces execution time on ordinary numerical code. Directed variants correspond to cocartesian fibrations; a related applied line of work is diagrammatic composition of PDE systems, whose reported gains remain qualitative.
Standing-wave mode structure of an RF discharge in a polyhedral cavity2012
2.45 GHz discharge in an evacuated aluminum polyhedron backfilled with argon; cavity geometry selects the supported resonant modes and the discharge organizes along the resulting standing wave. Motivated by deployable conductive structures in ionospheric plasma.
Benchtop analogue only: argon matches neither ion mass nor electron temperature, and discharge density sits orders of magnitude above ionospheric values.
Flexible TiO2 resistive-switching devices2012
Fabrication and characterization of memristive devices on compliant substrates, including switching behavior under bend cycling. Research assistantship, Mary Baldwin College.
Motivation was colocated storage and computation for body-worn sensing; now termed in-sensor and near-sensor computing.
Fragments
Structure recovered from the traces a language leaves behind.
Unsupervised grammar and lexicon induction from partially parallel text2013
Probabilistic lexicon induction over weakly parallel corpora, evaluated on contracted Grade 2 Braille, chosen as a test language with a known ground truth. Undergraduate thesis, George Mason University. Code.
This grew out of automated computational semantics research at GMU, which also included work on abstractive summarization of biomedical literature — getting a machine to read a scientific paper and return something faithful and short enough that a clinician could decide whether the full paper was worth their evening.
Generalizes to incompletely deciphered scripts. Applied motivation: transcription error in installed accessible signage.
Automated abstractive summarization of biomedical literature for clinical readers2013
Automated computational semantics directed at reducing a paper to a triage-sufficient summary. George Mason University.
Evaluation of evidence fidelity, rather than generation, remains the open problem.
THE PROOFS
PUBLICATIONS & PREPRINTS
On the Chromatic Splitting Conjecture at Coheight 1Sept 2026preprint
Moduli Stacks of G-Curves in Homotopy Theory at \(h = p-1\)Sept 2025submitted
Toward the p = 3 Kervaire Invariant ProblemJuly 2025submitted
Modeling Group Actions on Stacks (Especially the Lubin–Tate Action)July 2025preprint
Automorphisms of Abelian Varieties and Principal Polarizations2022published
Toward Directed Collapsibility2020published
A Global Crystalline Period Map2018preprint
IN PROGRESS
Zeta Functions in Homotopy Theory
Syntomic cohomology of ring spectra and a \(T(h)\)-local zeta function
Toward Categorifying the relationship of Symplectic L-functions and Reidemeister Torsion
L-genera and Localizations in K-theory
All Bernoulli Numbers in Homotopy Theory Are Shifts
Moduli Stacks of Curves in Homotopy Theory
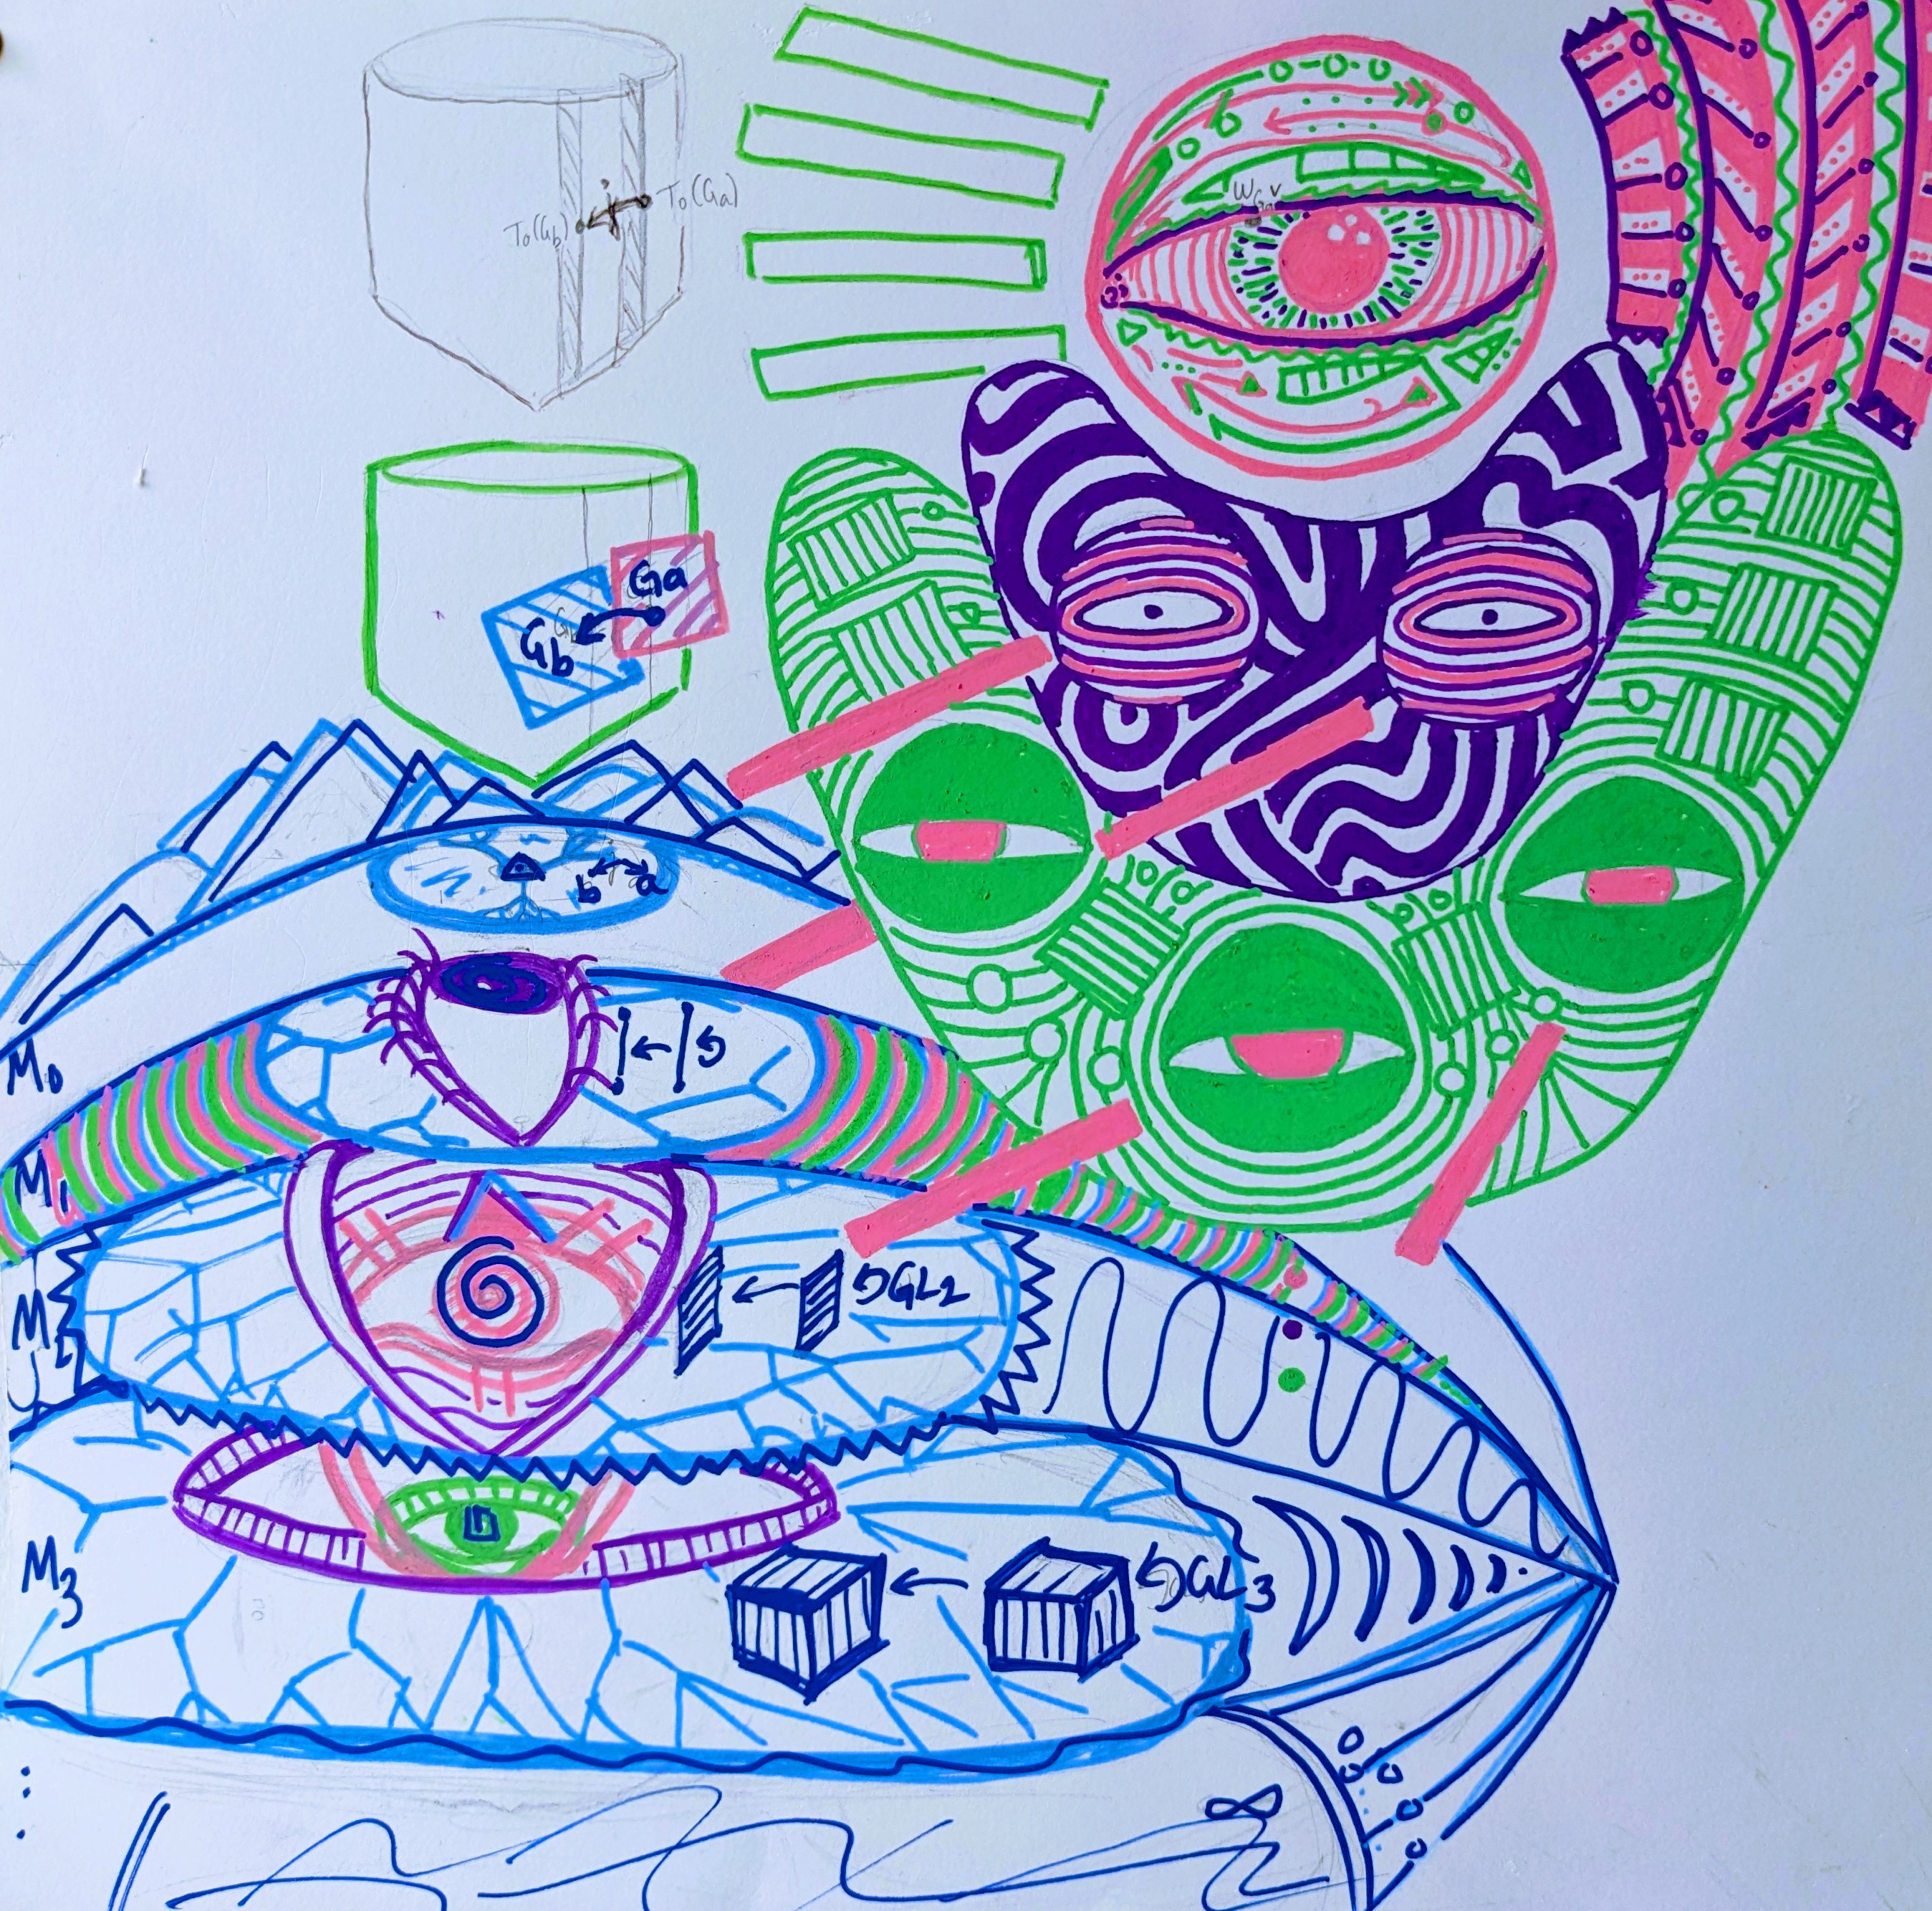
The group cohomology of the maximal finite subgroups of the Lubin–Tate action is the \(E_2\) page needed to capture all p-torsion information in the stable homotopy groups of spheres. My thesis (2023) attempts to resolve the 40-year-old open problem of describing the Lubin–Tate action for all maximal finite subgroups.
It does so by outlining a universal way to build a geometric model using a moduli stack of G-curves given a subgroup G. A key insight is to replace the role of level structures with higher ramification information. To make the thesis more digestible, I have broken it up into three parts, the last of which is forthcoming. The only nontrivial p-torsion for odd primes is found at heights \(p^{k-1}(p-1)\).
Writhing Jewels: A Conjectural Description of the Lubin–Tate Action via Moduli Stacks of G-Curves for \(h = p^{k-1}(p-1)\)
The Eigenvalues of Frobenius of Artin–Schreier–Witt Curves are Gauss Sums
EXPOSITORY
Zeta Functions and THH
Using Automorphism Groups of Curves to Control the Slopes of their Jacobians
K-theoretic Tate–Poitou Duality Seminarcoming soon
A 4-page summary of my graduate work for a general audience
Geometry for Prime Addicts
The Hecke Orbit Conjecture and Homotopy Theory
An Overview of the Classic Theory of p-Divisible Groups
Fiber Bundles of Formal Disks
A Complete Proof of the Polynomial Ham Sandwich Theorem
My two Master’s theses
TEACHING
stub An updated teaching statement is on its way; this is the current one.
I came into academia from outside, so I go out of my way to present mathematics in ways that are accessible to everyone. For me it is a visual, interactive, intuitive and artistic experience, and above all a narrative one. I keep learning materials for students of all levels on my resources page. My teaching statement:
THE STUDIO
Pastels, acrylic, spray-painted creature murals, tattoos, polaroids. A taste:


And beyond the gallery:
CONTACT ME
- Curiosity is welcome
- fractalcows@gmail.com
- My work email
- cray@uni-muenster.de
You will find the name Cathe(rin)e Ray on old stuff and Rin Ray on my newer works — these both refer to the same person. I prefer Rin nowadays.
Comments from the old blog (5)
Recovered from the Wayback Machine of the old site after my back-up servers got black-hatted.
I just wanna say that like this blog so much, and you remind me of the movie called: Proof 😉
Agreed. I don’t comment but visit and enjoy regularly.
Edward Frenkel was your mentor! WOW!
Hi
Good Morning…
Best of Luck for Future Work…
If you will come to India ..I will meet you…
Nice work
Hi Rin, just wanted to say how much you inspire to help young people like math. Keep it up. 🙂